Loading...
Searching...
No Matches
CANCore Class Referenceabstract
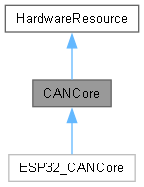
Inheritance diagram for CANCore:
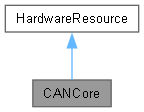
Collaboration diagram for CANCore:
Classes | |
| struct | CANMessage |
Public Types | |
| enum | Baudrate { BR_NOT_SET = 0 , BR_125K = 125000 , BR_250K = 250000 , BR_500K = 500000 , BR_1M = 1000000 } |
| enum | Status { STATUS_OK , STATUS_ERROR_ACTIVE , STATUS_BUS_OFF , STATUS_ERROR_PASSIVE } |
| enum | FilterType { FILTER_ACCEPT_ALL , FILTER_MATCH_ID , FILTER_MASKED } |
| Public Types inherited from HardwareResource | |
| enum | Type { UART , SPI , I2C , PWM , CAN } |
| Enumeration of hardware resource types. More... | |
Public Member Functions | |
| virtual bool | begin ()=0 |
| virtual bool | setBaudrate (Baudrate baudrate)=0 |
| virtual bool | setPins (int8_t txPin, int8_t rxPin)=0 |
| virtual bool | end ()=0 |
| virtual bool | sendMessage (const CANMessage &message)=0 |
| virtual bool | readMessage (CANMessage &message)=0 |
| virtual uint8_t | available ()=0 |
| virtual bool | setupFilter (uint32_t id, uint32_t mask)=0 |
| Baudrate | getBaudrate () const |
| uint8_t | getTxPin () const |
| uint8_t | getRxPin () const |
| virtual bool | reset () override |
| Reset the hardware resource to a known default state. | |
| Public Member Functions inherited from HardwareResource | |
| virtual Type | getType ()=0 |
| Get the hardware resource type. | |
| bool | requestUsage () |
| Request a usage slot for this resource. | |
| uint8_t | getUsages () |
| Get the current number of usages of this resource. | |
| bool | isUsed () |
| Check if the resource is currently used. | |
| virtual uint8_t | getRemainingUsages () |
| Get remaining usage capacity for this resource. | |
Protected Attributes | |
| Baudrate | _baudrate = BR_NOT_SET |
| FilterType | _filterType = FILTER_ACCEPT_ALL |
| int8_t | _txPin = -1 |
| int8_t | _rxPin = -1 |
| Status | _status = STATUS_OK |
| bool | _isInitialized = false |
| uint32_t | _filterId = 0 |
| uint32_t | _filterMask = 0 |
| Protected Attributes inherited from HardwareResource | |
| uint8_t | usages =0 |
| Current usage counter. | |
Additional Inherited Members | |
| Protected Member Functions inherited from HardwareResource | |
| HardwareResource ()=default | |
| Default constructor. | |
| virtual uint8_t | getMaxUsages () |
| Get the maximum simultaneous usages allowed for this resource. | |
Member Function Documentation
◆ available()
|
pure virtual |
Implemented in ESP32_CANCore.
◆ begin()
|
pure virtual |
Implemented in ESP32_CANCore.
◆ readMessage()
|
pure virtual |
Implemented in ESP32_CANCore.
◆ reset()
|
inlineoverridevirtual |
Reset the hardware resource to a known default state.
Default implementation clears the usage counter and logs the reset. Derived classes should call the base implementation and perform any additional hardware-specific reset steps.
- Returns
- true if the reset succeeded, false otherwise.
Reimplemented from HardwareResource.
Reimplemented in ESP32_CANCore.
Here is the call graph for this function:

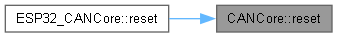
Here is the caller graph for this function:
◆ setBaudrate()
|
pure virtual |
Implemented in ESP32_CANCore.
◆ setPins()
|
pure virtual |
Implemented in ESP32_CANCore.
The documentation for this class was generated from the following file:
- C:/Users/leowa/Documents/PlatformIO/Projects/CANTramFrameworkUsage/lib/CANTramFramework/include/CANCore.h